01 / FIRMWAREEmbedded software
Production firmware for connected devices, controllers, and robotic systems, designed around explicit timing, ownership, and failure behavior.
Advanced Physical Systems Lab
APSL builds reusable software and engineering tools for robotics and other physical systems.
These projects predate APSL and are shown as Ajinkya Kamat's engineering background across industrial robotics, research manipulation, and original robot design.
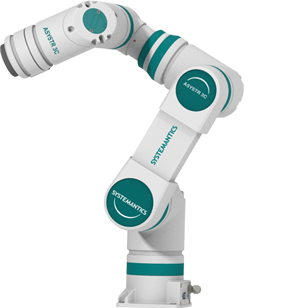
INDUSTRIAL ROBOTICSController electronics, motor-drive firmware, real-time Linux, ROS 2 architecture, and deployment infrastructure.
FIELD MANIPULATIONDebris-clearing manipulation, grasp selection, calibration, and C++ motion planning in unstructured environments.
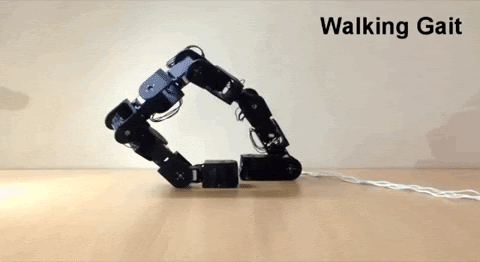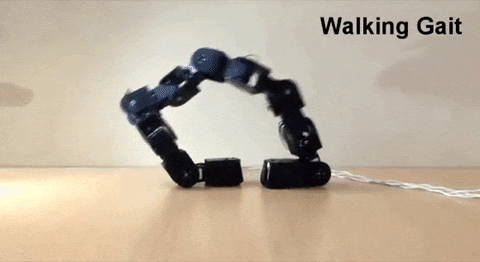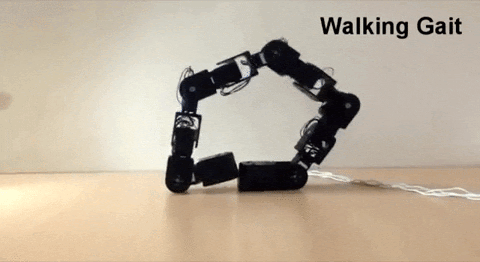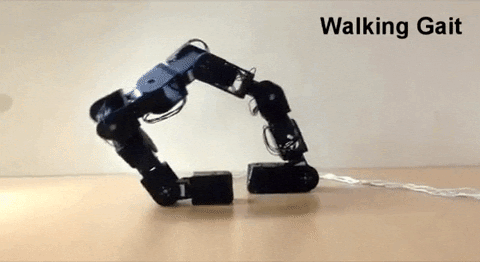
ORIGINAL ROBOTRobot and electronics design, reconfiguration and walking gaits, and genetic-algorithm gait generation.
01 / FIRMWAREProduction firmware for connected devices, controllers, and robotic systems, designed around explicit timing, ownership, and failure behavior.
02 / ARCHITECTUREClear boundaries between application logic, hardware, operating systems, protocols, and tooling—without unnecessary framework weight.
03 / ROBOTICSMotor-control applications, real-time coordination, telemetry, and hardware integration built for testability on the bench and in simulation.
04 / RELIABILITYBring-up, deep fault analysis, observability, and production hardening for systems that need to keep working outside the lab.
Small solutions with no architecture hiding behind them.
Types, timing, ownership, and failure are explicit.
Systems are tested against the conditions they will actually face.
Tell us what you are building, where it is stuck, and what success needs to look like.