 INDUSTRIAL ROBOTICS
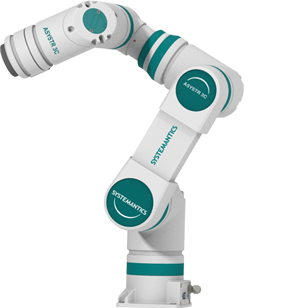
ASYSTR collaborative robots
Indigenously developed industrial manipulators built at Systemantics.
Contribution: Controller electronics, motor-drive firmware, real-time Linux, ROS 2 architecture, and deployment infrastructure.
Ajinkya Kamat · Prior work
A selection of industrial robots, research manipulators, and original robot platforms built across more than a decade. Several began at IvLabs, the student robotics community Ajinkya founded at VNIT and continues to mentor.
Prior work: these projects were developed through Systemantics, the University of Washington, Carnegie Mellon University, IvLabs, and other earlier collaborations. They are presented here as Ajinkya's engineering background, not as APSL projects.
INDUSTRIAL ROBOTICSIndigenously developed industrial manipulators built at Systemantics.
Contribution: Controller electronics, motor-drive firmware, real-time Linux, ROS 2 architecture, and deployment infrastructure.
 ASSISTIVE MANIPULATION
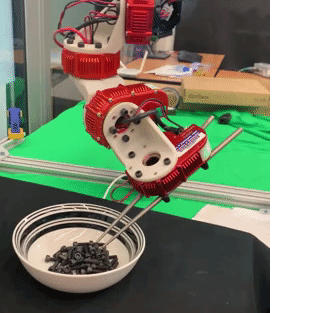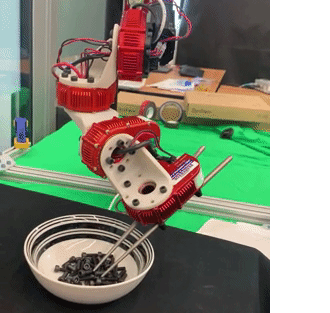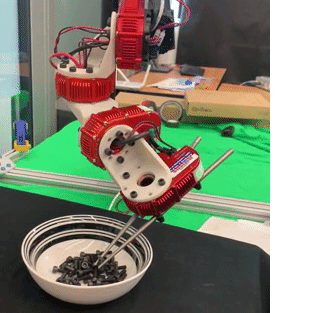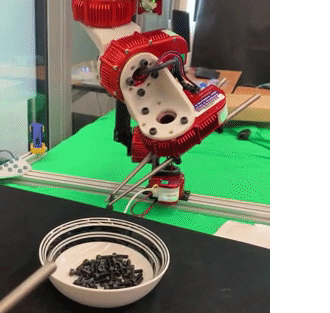
A six-degree-of-freedom arm using chopsticks as an end effector for food manipulation.
Contribution: Mechanical design, gravity compensation, Cartesian impedance control, teleoperation, and trajectory replay.
 FIELD MANIPULATION
A human-scale mobile manipulation platform for operating in cluttered, unstructured environments.
Contribution: Debris-clearing pipeline, grasp selection, limb-camera calibration, and C++ motion planning using Aikido.
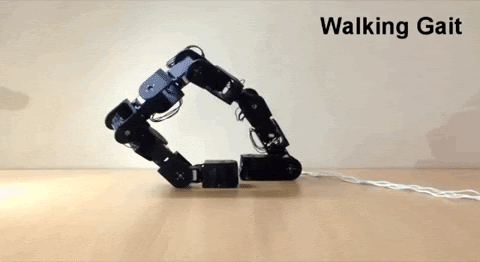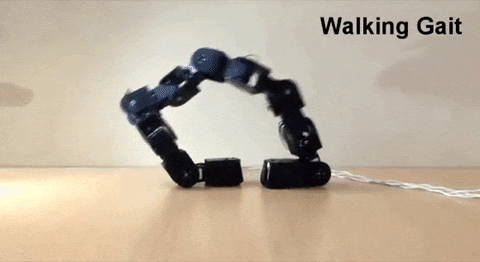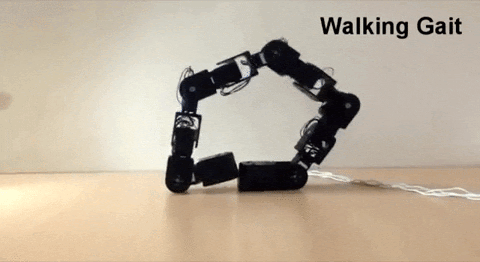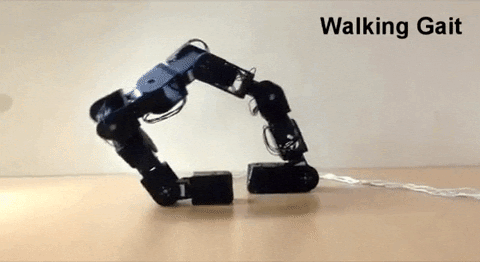 ORIGINAL ROBOT
A nine-degree-of-freedom snake robot that reconfigures into a stable biped without rearranging its modules.
Contribution: Robot and electronics design, reconfiguration and walking gaits, and genetic-algorithm gait generation.
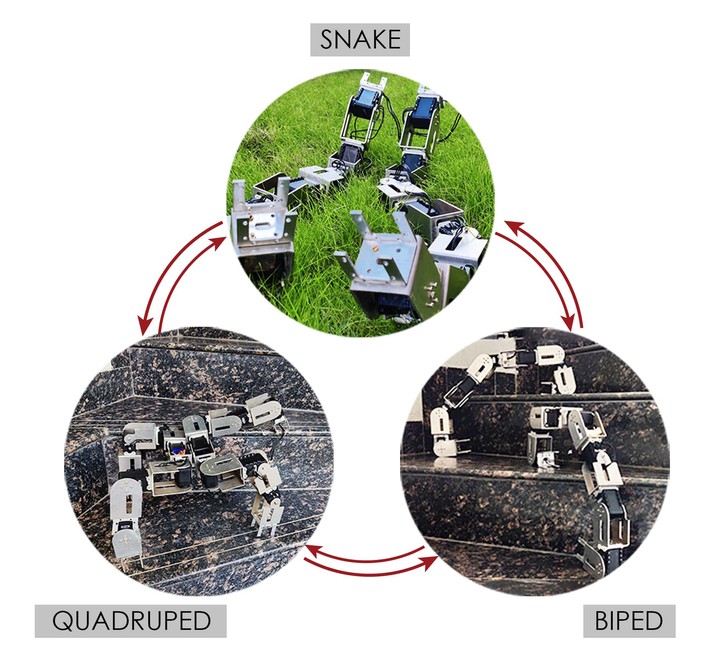 IVLABS · MENTORED
A modular snake robot capable of quadrupedal and bipedal configurations.
Contribution: Overall concept and long-term technical mentorship of the IvLabs student team.
 IVLABS · MENTORED
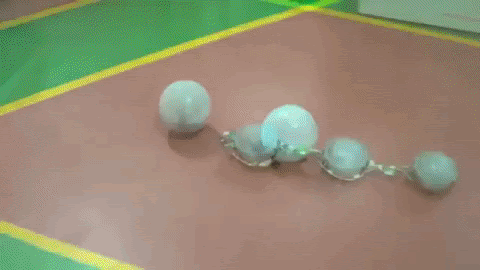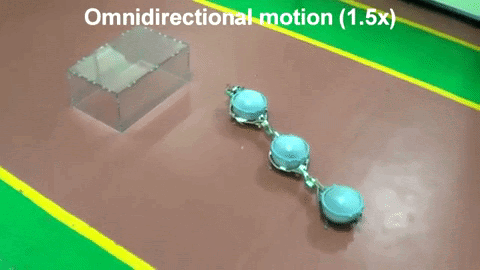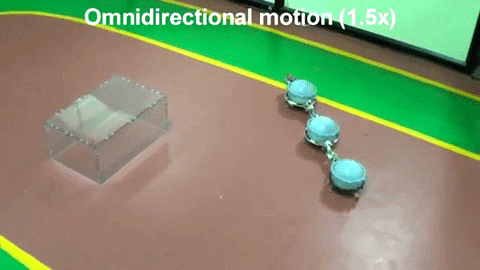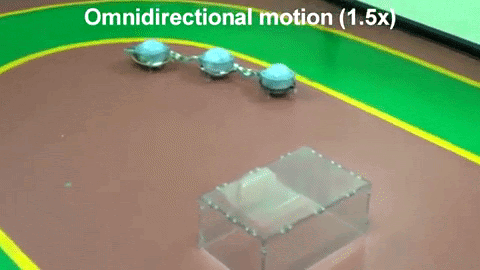
A spherical snake robot exploring a compact, shape-changing locomotion architecture.
Contribution: Initial prototype design, electronics support, and mentorship of the core IvLabs team.
 IVLABS · ASSISTIVE TECH
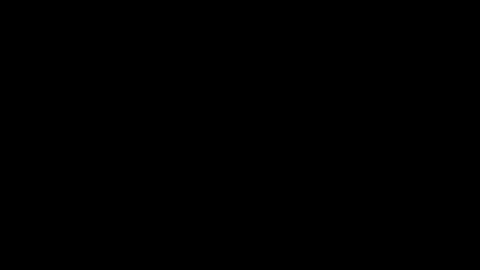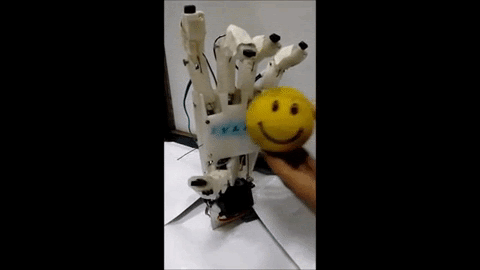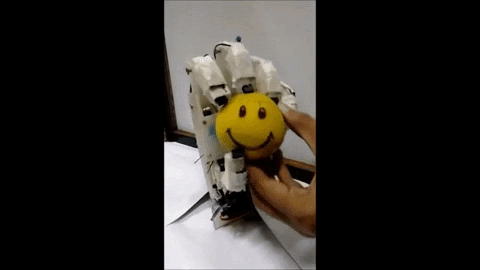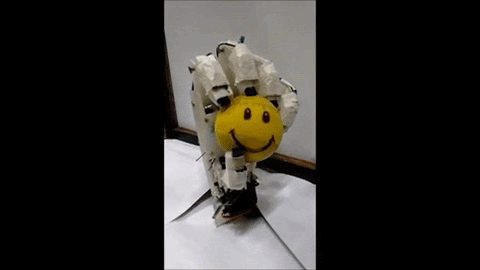
A low-cost prosthetic hand for below-elbow amputees using fingertip sensing to select grasps.
Contribution: Sensor and actuation scheme, grasp strategies, electronics support, and student-team mentorship.
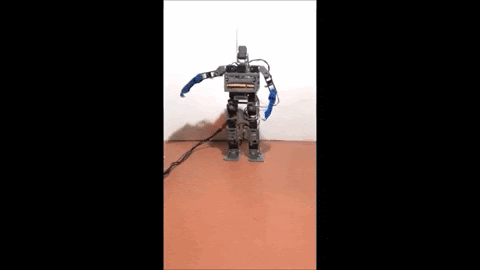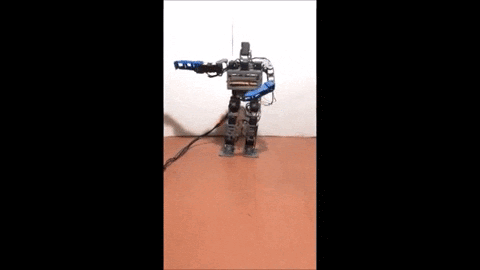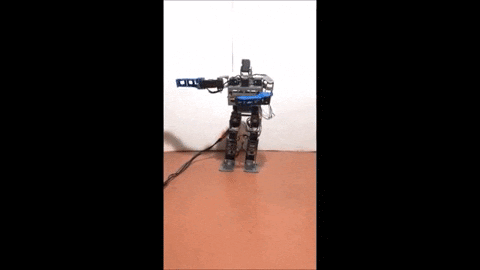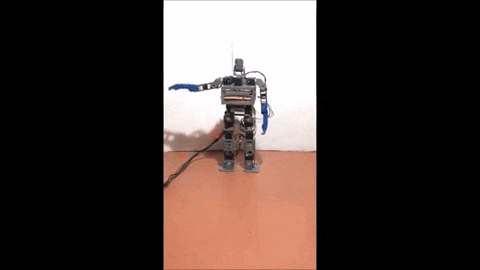 IVLABS · HUMANOID
A child-sized, twenty-degree-of-freedom humanoid robot developed at IvLabs.
Contribution: Electronics and software architecture, along with technical mentorship of the student team.
The projects span different institutions and generations of engineers, but share one approach: understand the physical mechanism, make the hardware and software boundaries explicit, and leave behind a system another engineer can extend.